a problem with the STM32F103 bluepill used in post 6 is indicated by the compiler warning
STM32_CAN.h:138:2: warning: #warning "CAN IRQ Handler is used by USBDevice driver
using USB Serial Monitor IO with the CAN interface is difficult (in practice one would probably use the Serial1 interface)
running STM32-CAN library example file>Examples>STM32_CAN/Read-Write_with_filters on a STM32F746ZG nucleo board
// STM32F746ZG nucleo board STM32-CAN library read/write test

// file>Examples>STM32_CAN/Read-Write_with_filters

/*
This example shows how to read filtered CAN messages from the bus and send data out using timers.
*/

#include "STM32_CAN.h"

static CAN_message_t CAN_outMsg_1;
static CAN_message_t CAN_outMsg_2;
static CAN_message_t CAN_outMsg_3;
static CAN_message_t CAN_inMsg;

// This will use PA11/12 pins for CAN1 and set RX-buffer size to 64-messages. TX-buffer size is kept at default 16.
//STM32_CAN Can( CAN1, DEF, RX_SIZE_64, TX_SIZE_16 );
STM32_CAN Can(CAN1, ALT, RX_SIZE_64, TX_SIZE_16);  //Use PB8/9 pins for CAN1.

uint8_t Counter;

void printData(CAN_message_t CAN_outMsg) {
  Serial.printf("Transmit frame: %03X: ", CAN_outMsg.id);
  for (byte i = 0; i < 8; i++)
    Serial.printf(" 0x%.2X", CAN_outMsg.buf[i]);
  Serial.printf("\n");
}

void SendData()  // Send can messages in 50Hz phase from timer interrupt.
{
  Serial.print("\nSending frame: ");
  Serial.println(Counter, HEX);
  //if (Counter >= 255){ Counter = 0;}
  // Only the counter value is updated to the 3 messages sent out.
  CAN_outMsg_1.buf[3] = Counter;
  Can.write(CAN_outMsg_1);
  printData(CAN_outMsg_1);
  CAN_outMsg_2.buf[5] = Counter;
  Can.write(CAN_outMsg_2);
  printData(CAN_outMsg_2);
  CAN_outMsg_3.buf[6] = Counter;
  Can.write(CAN_outMsg_3);
  printData(CAN_outMsg_3);
  Counter++;
}

void readCanMessage()  // Read data from CAN bus and print out the messages to serial bus. Note that only message ID's that pass filters are read.
{
  Serial.print("Channel:");
  Serial.print(CAN_inMsg.bus);
  if (CAN_inMsg.flags.extended == false) {
    Serial.print(" Standard ID:");
  } else {
    Serial.print(" Extended ID:");
  }
  Serial.print(CAN_inMsg.id, HEX);

  Serial.print(" DLC: ");
  Serial.print(CAN_inMsg.len);
  if (CAN_inMsg.flags.remote == false) {
    Serial.print(" buf: ");
    for (int i = 0; i < CAN_inMsg.len; i++) {
      Serial.print("0x");
      Serial.print(CAN_inMsg.buf[i], HEX);
      if (i != (CAN_inMsg.len - 1)) Serial.print(" ");
    }
    Serial.println();
  } else {
    Serial.println(" Data: REMOTE REQUEST FRAME");
  }
}

void setup() {
  Counter = 0;
  Serial.begin(115200);
  delay(2000);
  Serial.println("\n\nSTM32F746ZG nucleo board STM32-CAN library read/write test");
  Can.begin();
  Can.setBaudRate(125000);
  //Can.setBaudRate(500000);
  Can.setMBFilterProcessing(MB0, 0x100, 0x1FFFFFFF);
  Can.setMBFilterProcessing(MB1, 0x7DF, 0x1FFFFFFF);
  // You can also set that is the ID Standard or Extended
  Can.setMBFilterProcessing(MB2, 0x615, 0x1FFFFFFF, STD);
  Can.setMBFilterProcessing(MB3, 0x1F0, 0x1FFFFFFF, EXT);

  // We set the data that is static for the three different message structs once here.
  CAN_outMsg_1.id = (0x1A5);
  CAN_outMsg_1.len = 8;
  CAN_outMsg_1.buf[0] = 0x03;
  CAN_outMsg_1.buf[1] = 0x41;
  CAN_outMsg_1.buf[2] = 0x11;
  CAN_outMsg_1.buf[3] = 0x00;
  CAN_outMsg_1.buf[4] = 0x00;
  CAN_outMsg_1.buf[5] = 0x00;
  CAN_outMsg_1.buf[6] = 0x00;
  CAN_outMsg_1.buf[7] = 0x00;

  CAN_outMsg_2.id = (0x7E8);
  CAN_outMsg_2.len = 8;
  CAN_outMsg_2.buf[0] = 0x03;
  CAN_outMsg_2.buf[1] = 0x41;
  CAN_outMsg_2.buf[3] = 0x21;
  CAN_outMsg_2.buf[4] = 0x00;
  CAN_outMsg_2.buf[5] = 0x00;
  CAN_outMsg_2.buf[6] = 0x00;
  CAN_outMsg_2.buf[7] = 0xFF;

  CAN_outMsg_3.id = (0xA63);
  CAN_outMsg_3.len = 8;
  CAN_outMsg_3.buf[0] = 0x63;
  CAN_outMsg_3.buf[1] = 0x49;
  CAN_outMsg_3.buf[2] = 0x11;
  CAN_outMsg_3.buf[3] = 0x22;
  CAN_outMsg_3.buf[4] = 0x00;
  CAN_outMsg_3.buf[5] = 0x00;
  CAN_outMsg_3.buf[6] = 0x00;
  CAN_outMsg_3.buf[7] = 0x00;
  /*
  // setup hardware timer to send data in 50Hz pace
  #if defined(TIM1)
  TIM_TypeDef *Instance = TIM1;
#else
  TIM_TypeDef *Instance = TIM2;
#endif
  HardwareTimer *SendTimer = new HardwareTimer(Instance);
  SendTimer->setOverflow(50000, HERTZ_FORMAT); // 50 Hz
#if ( STM32_CORE_VERSION_MAJOR < 2 )
  SendTimer->attachInterrupt(1, SendData);
  SendTimer->setMode(1, TIMER_OUTPUT_COMPARE);
#else //2.0 forward
  SendTimer->attachInterrupt(SendData);
#endif
  SendTimer->resume();
  */
  SendData(); // send initial frame
}

// main loop
void loop() {
  // if key entered send a frame
  if (Serial.available()) {
    while (Serial.available()) Serial.read();
    SendData();
  }
  // The actual code that is being used will be done to main loop as usual.
  // We only read data from CAN bus if there is frames received, so that main code can do it's thing efficiently.
  while (Can.read(CAN_inMsg)) {
    readCanMessage();
  }
}
Serail monitor output
STM32F746ZG nucleo board STM32-CAN library read/write test

Sending frame: 0
Transmit frame: 1A5:  0x03 0x41 0x11 0x00 0x00 0x00 0x00 0x00
Transmit frame: 7E8:  0x03 0x41 0x00 0x21 0x00 0x00 0x00 0xFF
Transmit frame: A63:  0x63 0x49 0x11 0x22 0x00 0x00 0x00 0x00
Channel:1 Standard ID:100 DLC: 8 buf: 0x0 0x4D 0x45 0x47 0x41 0x0 0x7 0x8
Channel:1 Standard ID:100 DLC: 8 buf: 0x1 0x4D 0x45 0x47 0x41 0x0 0x7 0x8
Channel:1 Standard ID:7DF DLC: 8 buf: 0x2 0x54 0x57 0x41 0x49 0x0 0xAA 0xAA
Channel:1 Standard ID:7DF DLC: 8 buf: 0x3 0x54 0x57 0x41 0x49 0x0 0xAA 0xAA

Sending frame: 1
Transmit frame: 1A5:  0x03 0x41 0x11 0x01 0x00 0x00 0x00 0x00
Transmit frame: 7E8:  0x03 0x41 0x00 0x21 0x00 0x01 0x00 0xFF
Transmit frame: A63:  0x63 0x49 0x11 0x22 0x00 0x00 0x01 0x00

Sending frame: 2
Transmit frame: 1A5:  0x03 0x41 0x11 0x02 0x00 0x00 0x00 0x00
Transmit frame: 7E8:  0x03 0x41 0x00 0x21 0x00 0x02 0x00 0xFF
Transmit frame: A63:  0x63 0x49 0x11 0x22 0x00 0x00 0x02 0x00
Channel:1 Standard ID:100 DLC: 8 buf: 0x2 0x4D 0x45 0x47 0x41 0x0 0x7 0x8
Channel:1 Standard ID:100 DLC: 8 buf: 0x3 0x4D 0x45 0x47 0x41 0x0 0x7 0x8
Channel:1 Standard ID:7DF DLC: 8 buf: 0x4 0x54 0x57 0x41 0x49 0x0 0xAA 0xAA
Channel:1 Standard ID:7DF DLC: 8 buf: 0x5 0x54 0x57 0x41 0x49 0x0 0xAA 0xAA
Channel:1 Standard ID:7DF DLC: 8 buf: 0x6 0x54 0x57 0x41 0x49 0x0 0xAA 0xAA

Sending frame: 3
Transmit frame: 1A5:  0x03 0x41 0x11 0x03 0x00 0x00 0x00 0x00
Transmit frame: 7E8:  0x03 0x41 0x00 0x21 0x00 0x03 0x00 0xFF
Transmit frame: A63:  0x63 0x49 0x11 0x22 0x00 0x00 0x03 0x00
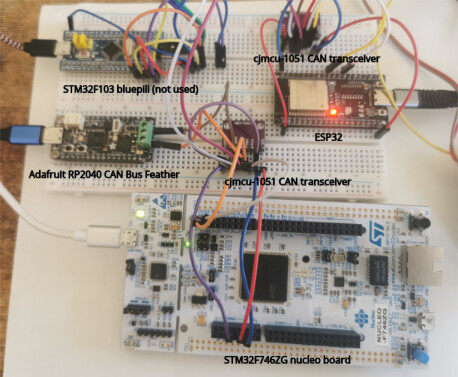
test setup (included a STM32F746ZG nucleo board, Adafruit RP2040 CAN Bus Feather, ESP32 and UNO+CAN shield)